Description
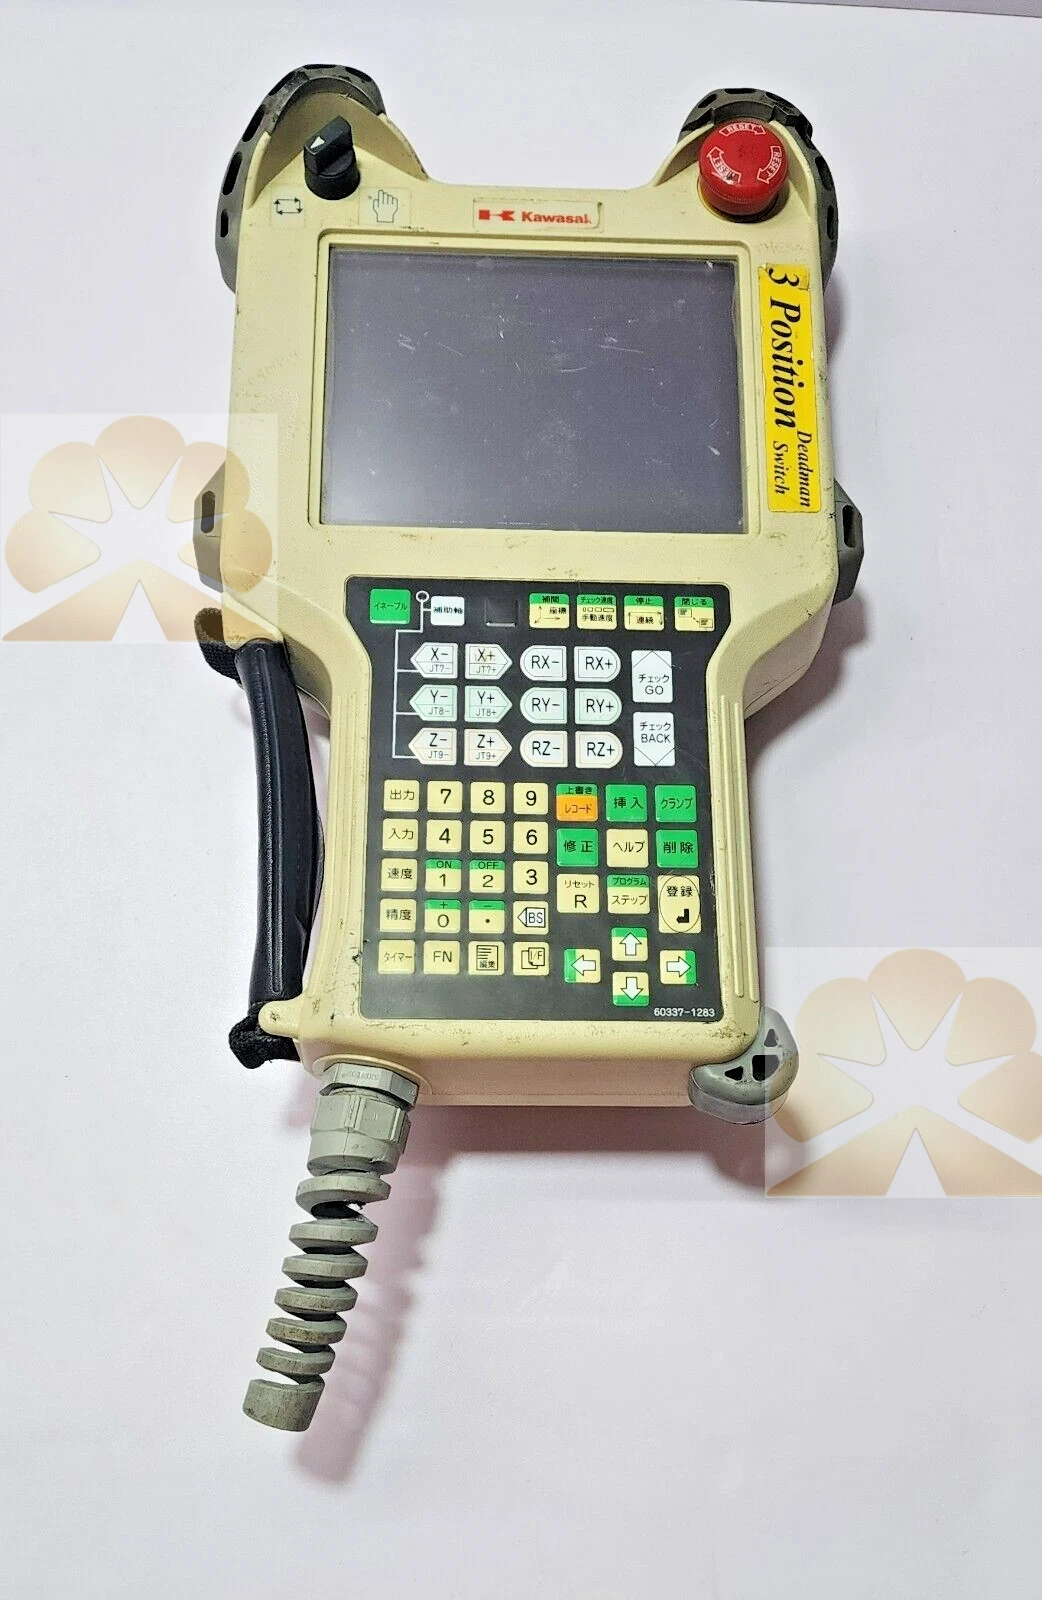
Kawasaki 50817-1384 Robot Teach Pendant Product Description
Overview
Kawasaki 50817-1384 is a robot teach pendant for Kawasaki robot controller, matching the 50817 series handheld operator unit family (50817-1381 / 50817-1384 variants). This 50817-1384 is the handheld programming unit used to jog axes, write robot programs, set parameters, monitor alarms and perform manual operation for Kawasaki industrial robots. It is widely used for welding, handling, palletizing and assembly robot cell maintenance and spare‑part replacement of Kawasaki teach pendants.
Features
Kawasaki 50817-1384 integrates color LCD display, membrane function keypad, 3-position enabling deadman switch and emergency stop button. This teach pendant supports jogging in joint / world / tool / user coordinate modes, program editing, teach point recording, cycle start and single-step execution. 50817-1384 communicates with the robot main controller via dedicated pendant cable, uploading position data and downloading robot programs. It displays real-time axis position, servo status, alarm codes and I/O signal status. The 3-stage deadman safety switch conforms to robot safety standards; servo power is only enabled when the button is held in the middle position. It has a rugged handheld plastic housing, dust and splash resistance for workshop environment. Different suffix variants (1381 /1384) differ in firmware version, key layout and compatible controller generation and cannot be swapped casually.
Specs
Brand: Kawasaki
Model: 50817-1384
Type: Robot teach pendant
Display: Color LCD
Safety: 3-position deadman switch, built-in E-stop
Operation: Jog, program teach, parameter setup, alarm monitoring
Connection: Dedicated communication cable to Kawasaki robot cabinet
Mounting: Handheld, with storage hook
Compatible: Corresponding Kawasaki robot controller generation
Status: Robot spare pendant
Principle
Kawasaki 50817-1384 sends jog commands, coordinate selection and program operation instructions to the robot controller. The controller returns axis position, servo state and fault information to the pendant screen. The deadman switch provides safety enabling signal; when released or fully pressed, the servo power is cut off immediately. The teach pendant stores temporary operation data, and robot programs are saved on the main controller.
Applications
Kawasaki 50817-1384 is deployed on spot welding robots, arc welding robots, material handling robots, palletizing robots and automated assembly cells. This Kawasaki teach pendant is the main manual operation tool for robot commissioning and troubleshooting. 50817-1384 fits robot cell overhaul and spare replacement of Kawasaki 50817 series teach pendants.
Installation & Maintenance Notes
Follow official Kawasaki robot manual during replacement of 50817-1384. Power off the robot controller before plugging/unplugging the pendant connector. Inspect cable, connector pins and deadman switch function regularly. After replacement, verify E-stop circuit, enabling loop, jog movement and screen touch/key response. Confirm exact part number 50817-1384; 50817-1381 and other variants have different firmware and controller compatibility.
Get a Quote